Collaborative Multi-Domain Autonomous Systems: Engineering the Next Generation of Distributed Aerospace Operations
APEX Autonomous & APEX Advanced Systems | Published: October 8th, 2026
Introduction
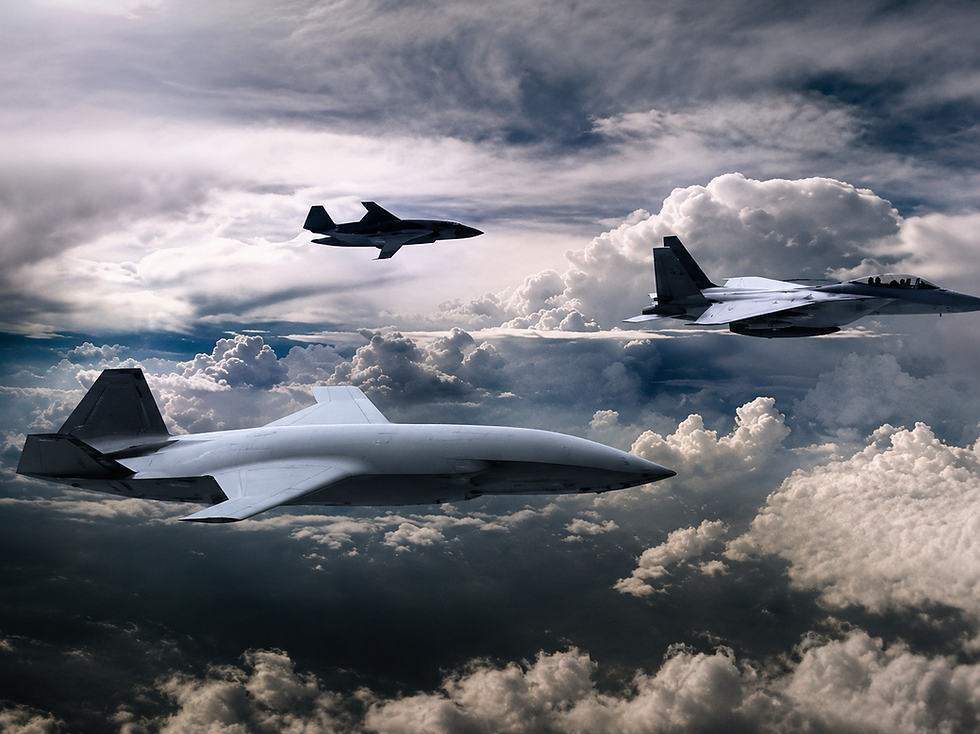
The aerospace environment of the future will not be defined by individual platforms operating independently, but by interconnected systems capable of sensing, communicating, reasoning, and coordinating across multiple operational domains. Collaborative Multi-Domain Autonomous Systems represent a transition from platform-centric engineering toward distributed architectures in which aircraft, spacecraft, unmanned systems, ground infrastructure, maritime assets, and intelligent software operate as components of a larger technological ecosystem. At APEX Aerospace, our research is focused on understanding the engineering principles required to enable these systems to collaborate effectively while maintaining resilience, adaptability, and human oversight.
The significance of multi-domain autonomy extends beyond simply connecting autonomous platforms to a common network. A truly collaborative architecture must allow heterogeneous systems with different sensors, computational capabilities, operating environments, and mission responsibilities to exchange information and coordinate behavior despite incomplete information, degraded communications, and constantly changing conditions. This creates a multidisciplinary engineering challenge involving autonomy, artificial intelligence, aerospace systems, communications, cybersecurity, robotics, control theory, and human–machine interaction.
From Platform-Centric to Distributed Systems
Traditional aerospace development has historically emphasized the optimization of individual platforms. Aircraft are designed around specific missions, spacecraft around specific orbital functions, and autonomous vehicles around narrowly defined operational requirements. While this approach remains valuable, increasingly complex operational environments require systems capable of functioning collectively rather than independently.
APEX is investigating a distributed systems philosophy in which individual platforms become nodes within a larger collaborative architecture. Under this model, an autonomous aircraft does not necessarily need to possess every capability required to accomplish a mission independently. Instead, it can leverage information, sensing, communications, computation, or specialized capabilities provided by other nodes within the network.
This architecture creates the possibility of distributing mission responsibilities across large numbers of comparatively specialized systems. Instead of relying upon a single highly capable platform, future aerospace architectures could combine numerous complementary systems whose collective capabilities exceed those of any individual vehicle.
Multi-Domain Systems Integration
A defining characteristic of multi-domain autonomy is the ability to coordinate activity across environments governed by fundamentally different physical and operational constraints. Atmospheric vehicles operate within dynamic aerodynamic environments, spacecraft operate within orbital mechanics, ground systems interact with terrestrial infrastructure, and maritime platforms operate within complex fluid environments.
The challenge is therefore not simply establishing communications between domains. Engineers must develop common information architectures through which systems can interpret and utilize information generated by fundamentally different platforms.
APEX research examines this challenge through a systems-of-systems perspective. Rather than treating air, space, ground, maritime, and autonomous systems as isolated technological categories, we investigate how their capabilities can be integrated into a unified architecture capable of supporting distributed sensing, collaborative decision-making, and coordinated mission execution.
Distributed Intelligence
Centralized command architectures can become increasingly vulnerable as the number of autonomous systems increases. A single computational or communications node responsible for coordinating an entire network may introduce bottlenecks, latency, and single points of failure.
Distributed intelligence provides an alternative. Computational responsibilities can be divided among multiple platforms, allowing individual nodes to process information locally while sharing relevant conclusions with the larger network. This architecture can reduce communication requirements and enable systems to continue functioning when portions of the network become unavailable.
APEX is exploring distributed autonomy models in which decision-making exists across multiple levels of the architecture. Individual platforms maintain local control authority while higher-level systems coordinate broader objectives. This creates a hierarchical yet flexible structure capable of balancing centralized mission intent with decentralized execution.
Collaborative Perception and Sensor Fusion
A distributed autonomous network can possess a substantially greater understanding of its environment than any individual platform. Aircraft, spacecraft, unmanned vehicles, ground stations, and other sensors can collectively contribute observations to a shared representation of the operational environment.
Collaborative perception requires sophisticated sensor-fusion architectures capable of reconciling information from sensors with different accuracies, update rates, perspectives, and environmental limitations. The system must determine which observations are reliable, identify correlations between observations, and continuously update its understanding as new information becomes available.
APEX research considers collaborative sensing as a foundational capability for multi-domain autonomy. Rather than asking what a single platform can observe, the engineering problem becomes determining what the entire network can collectively understand—and how that understanding can be transformed into useful information for human operators and autonomous systems.
Dynamic Mission Allocation
A major advantage of collaborative autonomy is the ability to dynamically distribute tasks among available systems. Static mission plans can become inefficient when environmental conditions change, individual platforms experience failures, or mission priorities evolve.
Dynamic task allocation allows autonomous systems to redistribute responsibilities according to changing circumstances. A system experiencing degraded performance could relinquish selected responsibilities while another node assumes them. Similarly, newly available information could cause the network to reprioritize sensing, communications, transportation, or other mission functions.
APEX is examining algorithmic approaches to dynamic resource allocation in which mission objectives remain stable while individual task assignments remain flexible. This distinction between what the system must accomplish and how the system accomplishes it is fundamental to creating resilient autonomous architectures.
Resilient Communications
Connectivity is one of the most important enabling technologies for collaborative autonomous systems. However, future multi-domain environments cannot assume continuous, high-bandwidth communication between every node.
Atmospheric interference, terrain, distance, orbital geometry, equipment failures, electromagnetic congestion, and other factors can create intermittent connectivity. A robust architecture must therefore be capable of operating across variable communication conditions.
Our research emphasizes resilient networking architectures capable of adapting to changing connectivity. Systems should be capable of prioritizing critical information, operating with delayed data, maintaining local autonomy during communication interruptions, and synchronizing information when connectivity becomes available again.
The objective is not to eliminate communication failures, but to engineer systems that remain useful when failures inevitably occur.
Edge Computing and Autonomous Decision-Making
The increasing availability of high-performance onboard computing enables autonomous systems to process information closer to where it is generated. This concept, commonly described as edge computing, can significantly reduce the dependence on centralized processing infrastructure.
For multi-domain aerospace systems, onboard processing can enable rapid interpretation of sensor data, local environmental assessment, autonomous navigation, and mission-level decision support without requiring every piece of information to travel through a centralized architecture.
APEX research examines the relationship between onboard intelligence and network-level intelligence. The optimal architecture may not place all computational authority in either individual platforms or centralized infrastructure. Instead, computing resources can be distributed according to latency requirements, available bandwidth, energy limitations, mission importance, and system resilience.
Human–Machine Collaboration
Increasing autonomy does not eliminate the importance of human decision-making. Instead, it changes where human operators provide the greatest value. Humans are particularly effective at establishing objectives, interpreting ambiguous circumstances, applying broader contextual judgment, and making decisions involving strategic priorities.
Autonomous systems, meanwhile, can excel at rapidly processing large quantities of information, maintaining continuous observation, and coordinating repetitive or computationally intensive activities.
APEX therefore views multi-domain autonomy as a human–machine partnership rather than an effort to remove humans from the system. Human operators should be able to establish intent, monitor system behavior, modify priorities, and intervene when necessary while allowing autonomous systems to manage appropriate lower-level functions.
Interoperability and Modular Architectures
A multi-domain autonomous ecosystem cannot depend upon every platform being manufactured by the same organization or using identical technologies. Long-term scalability requires interoperability.
APEX is investigating modular architectures in which sensors, communication systems, autonomy software, computing resources, and mission capabilities can be integrated through standardized interfaces. Modular systems can simplify upgrades, enable technology insertion, and reduce dependence upon a single hardware or software architecture.
This approach also supports evolutionary development. Rather than replacing an entire platform whenever a new technology becomes available, individual components can potentially be upgraded while preserving the larger system architecture.
Cybersecurity and System Resilience
As autonomous systems become increasingly interconnected, cybersecurity becomes inseparable from system engineering. A compromise of one node can potentially influence other systems if trust relationships and network boundaries are poorly designed.
Multi-domain architectures therefore require security mechanisms capable of establishing system identity, validating information, protecting communications, isolating compromised components, and maintaining operational functionality under adverse conditions.
APEX research approaches cybersecurity as a foundational architectural requirement rather than an additional layer applied after development. Resilience must be incorporated from the beginning of the design process, with systems engineered to tolerate component failures, corrupted information, communication disruptions, and other forms of operational uncertainty.
Digital Engineering and Simulation
The complexity of multi-domain autonomous systems makes physical testing alone impractical during early development. Engineers must be able to model interactions between large numbers of heterogeneous systems before deploying them in real environments.
Digital engineering provides an important foundation for this process. High-fidelity simulations can represent autonomous vehicles, communication networks, environmental conditions, sensors, human operators, and mission objectives within a common virtual environment.
APEX is investigating digital-twin and simulation-based methodologies that allow collaborative autonomy architectures to be evaluated across thousands of possible scenarios. Such environments can expose unexpected system behaviors, identify architectural weaknesses, and provide engineers with data necessary to refine autonomy algorithms before physical testing.
Emergent System Behavior
One of the most important research challenges involves understanding emergent behavior within large autonomous networks. When individual systems interact according to relatively simple rules, the collective network can exhibit behaviors that were not explicitly programmed into any single platform.
This characteristic creates both opportunities and risks. Emergent coordination could enable highly efficient resource utilization and adaptive mission behavior. Conversely, poorly designed interactions could produce instability, conflicting objectives, or unexpected system responses.
APEX research therefore emphasizes system-level verification rather than evaluating autonomous platforms exclusively in isolation. Engineers must understand not only whether individual systems behave correctly, but whether the interactions between those systems produce predictable and desirable collective behavior.
Future Aerospace Ecosystems
The long-term evolution of multi-domain autonomy could produce aerospace architectures fundamentally different from today’s conventional force structures. Instead of organizing capabilities around a limited number of large platforms, future systems may combine crewed aircraft, autonomous vehicles, orbital infrastructure, distributed sensors, communications networks, and intelligent software into continuously adapting ecosystems.
Such architectures could support persistent sensing, distributed logistics, autonomous infrastructure management, scientific exploration, disaster response, transportation, and other applications extending well beyond defense. The underlying engineering principles—distributed intelligence, resilient communications, modularity, collaborative perception, and adaptive coordination—are broadly applicable across aerospace.
At APEX Aerospace, our research is directed toward understanding these foundational principles and determining how they can be translated into practical architectures capable of scaling from individual autonomous platforms to large multi-domain ecosystems.
Future Research Directions
The next generation of research will increasingly focus on the interfaces between autonomous systems rather than autonomy within individual machines. Advances in distributed artificial intelligence, machine reasoning, edge computing, secure networking, adaptive control, digital twins, and autonomous coordination will provide the technological foundation for increasingly sophisticated collaborative architectures.
APEX intends to continue examining how these technologies can be integrated into scalable systems-of-systems architectures. Particular attention will be placed on interoperability, resilience, human oversight, verification, and the ability of autonomous networks to adapt without sacrificing predictability or system-level control.
The ultimate objective is to create architectures in which autonomous capabilities can expand organically as new platforms and technologies are introduced. Such an approach could allow future aerospace ecosystems to evolve continuously rather than requiring complete redesign whenever technological requirements change.
Conclusion
Collaborative Multi-Domain Autonomous Systems represent a fundamental transition in aerospace engineering—from isolated platforms toward interconnected, intelligent, and adaptive systems capable of operating collectively across multiple environments. The central engineering challenge is not simply creating autonomous machines, but creating architectures through which those machines can understand one another, share information, allocate responsibilities, and coordinate their behavior while remaining resilient to uncertainty and disruption.
At APEX Aerospace, our research treats multi-domain autonomy as a systems-of-systems problem requiring advances across artificial intelligence, aerospace engineering, robotics, communications, cybersecurity, control theory, human factors, and digital engineering. The future aerospace ecosystem will increasingly depend upon the ability to integrate these disciplines into architectures that are modular, scalable, resilient, and intelligently coordinated.
The most significant advancement may ultimately come not from making any individual platform dramatically more capable, but from enabling many different systems to function as components of a single intelligent ecosystem. By developing the engineering foundations for collaborative autonomy across air, space, terrestrial, and other operational domains, APEX is exploring a future in which aerospace systems are no longer defined solely by what individual machines can accomplish, but by what the network can accomplish together.


Comments